Home
Open source · MCP server

ardupilot-mcp — Flight Log Diagnosis Tool

An open-source MCP server that reads ArduPilot flight logs (.bin and .tlog) and explains in plain language why a drone crashed or flew badly. A deterministic check engine produces the findings; the AI only explains them.

ardupilot-mcp — Flight Log Diagnosis Tool

Highlights

deterministic checks
18
read-only tools
12
real crash logs benchmarked
49
Role
Sole developer
Period
2026
Field
UAV and drones · Autonomy, AI and vision · Web, desktop and mobile
Status
Open source · MCP server

Tech stack

  • Python
  • MCP
  • ArduPilot
  • MAVLink
  • Açık Kaynak
01 · Overview

Overview

ardupilot-mcp is an MCP (Model Context Protocol) server with no window of its own: it plugs into an AI client such as Claude Desktop, Cursor or VS Code. Give it a drone's ".bin" flight log or a ground station's ".tlog" telemetry and ask "why did it crash?"; the client explains vibration, low battery, GPS loss, motor loss or a bad setting in your own words.
02 · Problem

The Problem

A typical ArduPilot log has over 100,000 rows; reading vibration, EKF, battery and attitude traces after a crash takes time and experience. Existing tools (Mission Planner Auto Analysis, UAV Log Viewer) show the data but leave interpretation to the user — neither answers "why did this happen?" with reasoning or takes natural-language follow-up questions.

03 · Solution

Deterministic Check Engine

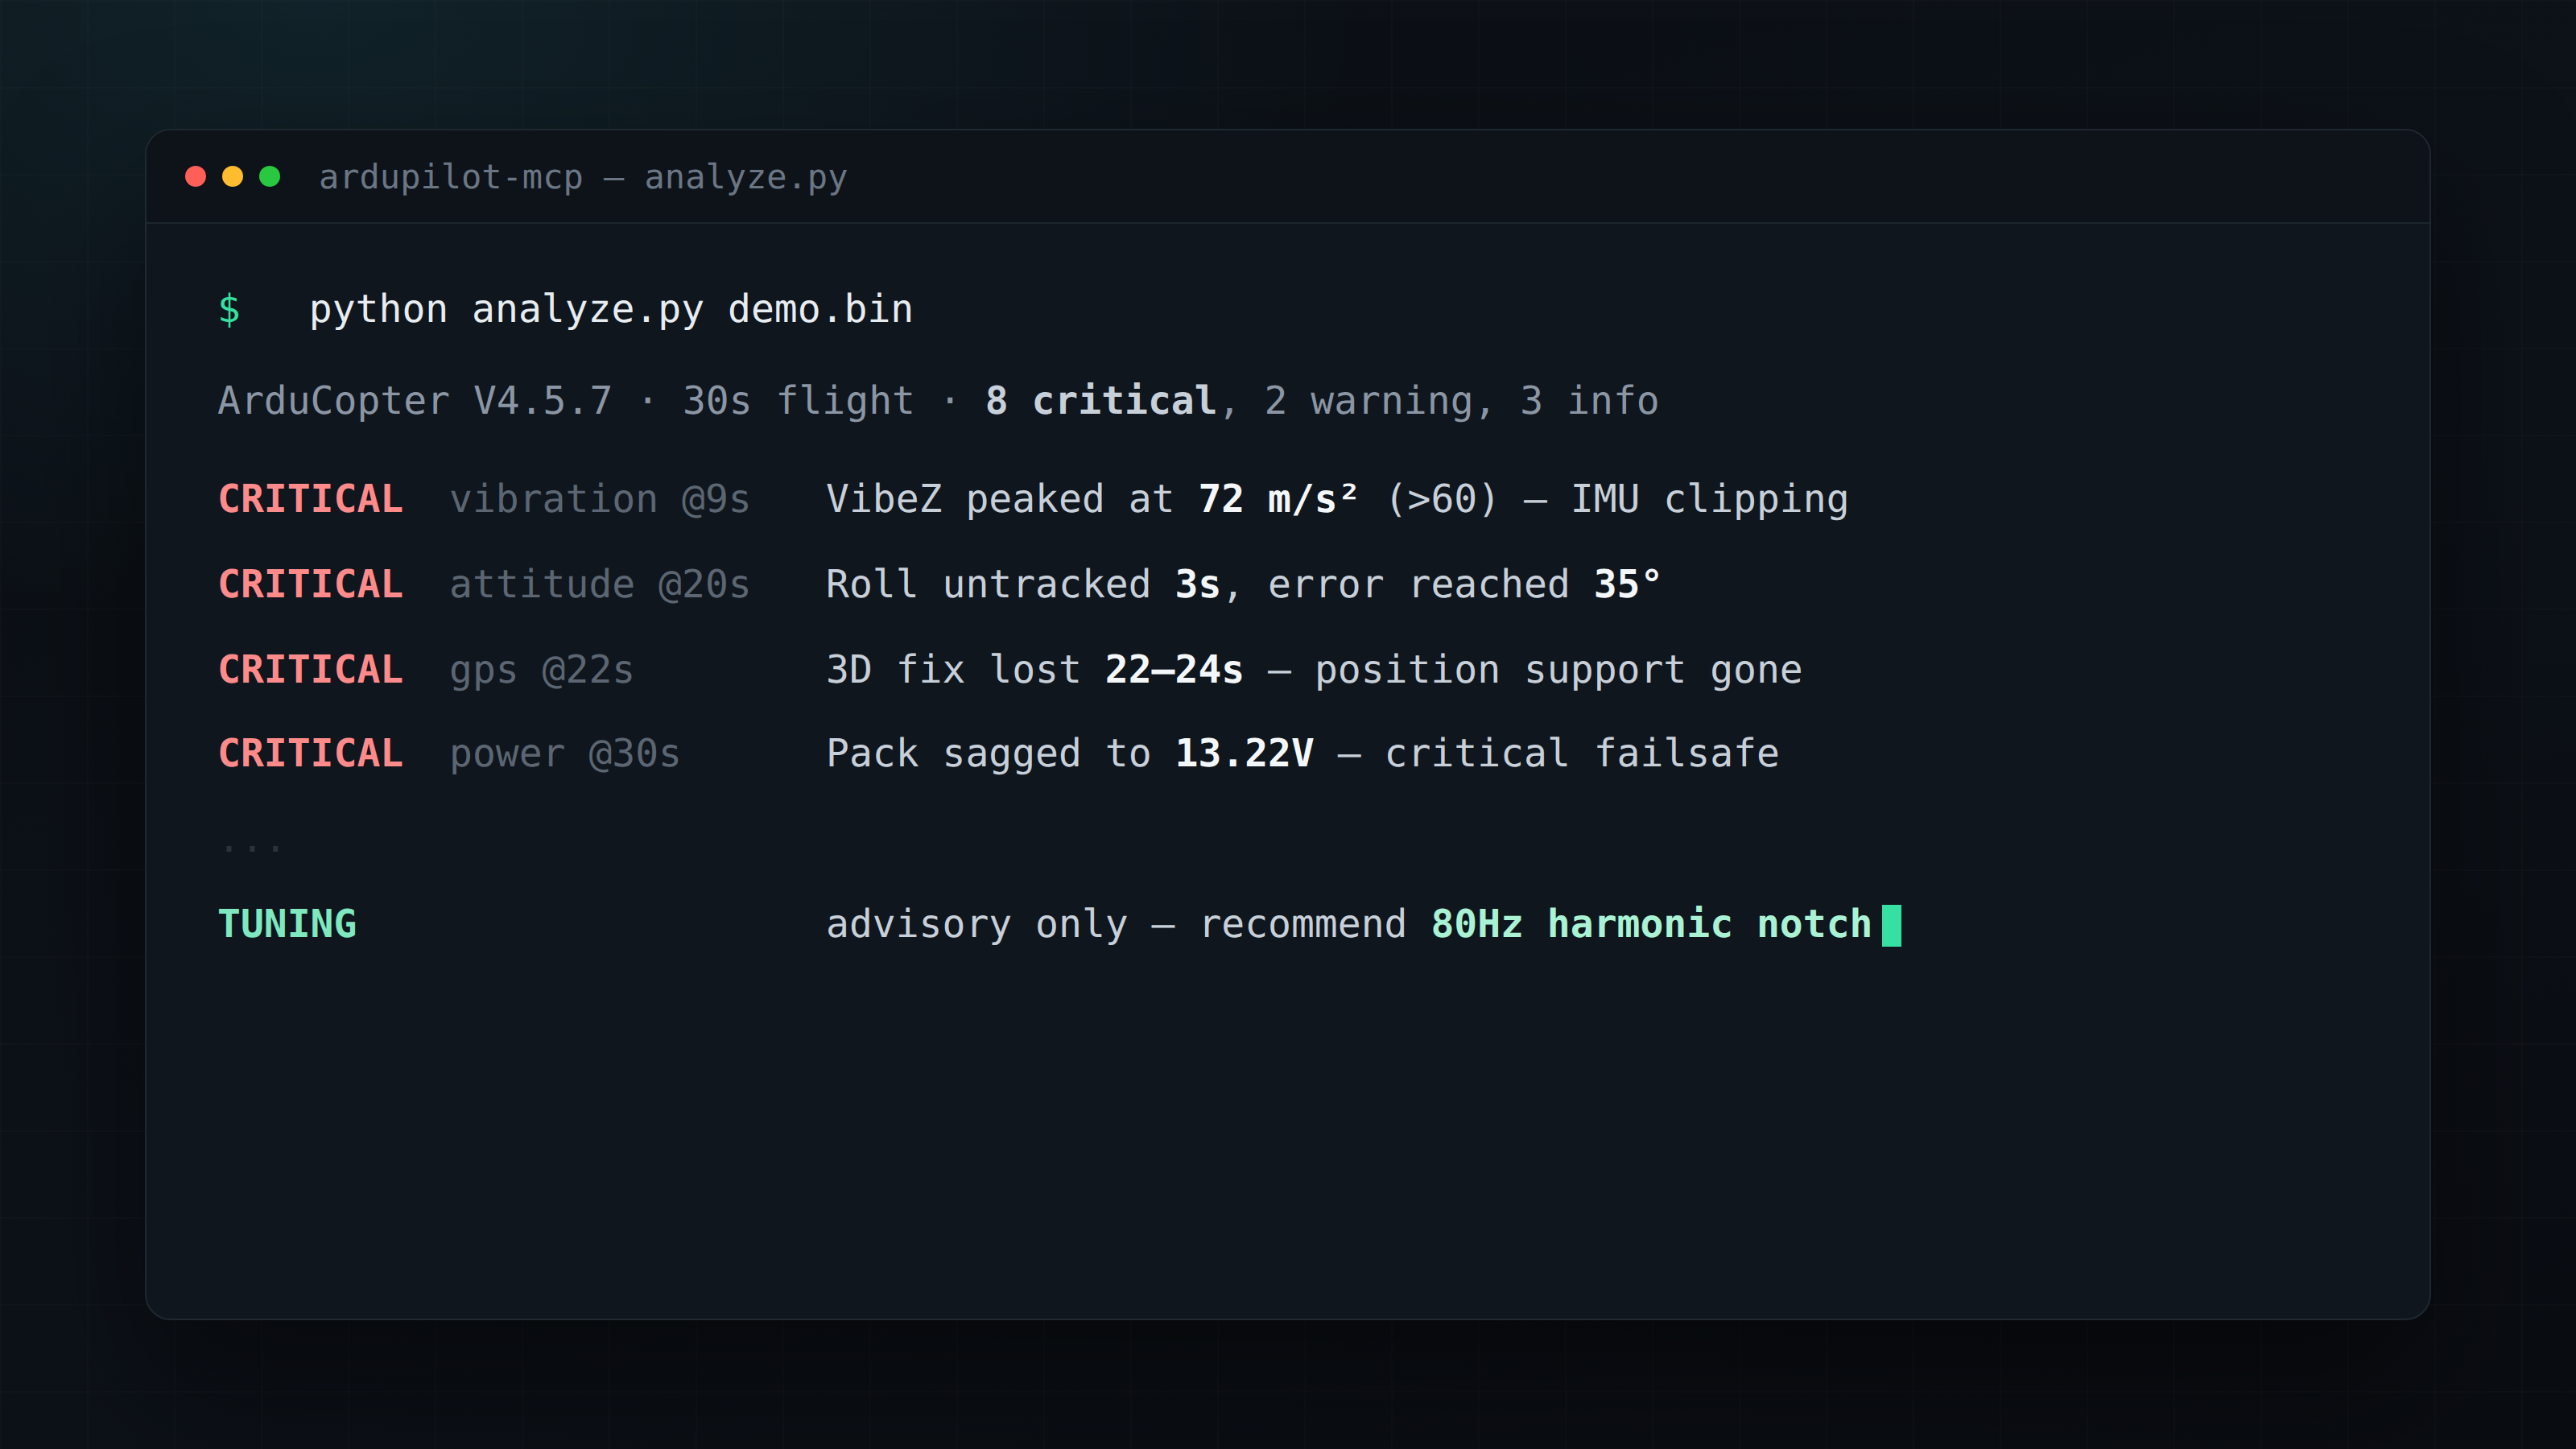
18 checks cover flight dynamics (vibration, EKF, GPS, power, attitude, RC loss) and setup faults (wiring, calibration, bad parameters, power margin), each threshold with a documented source. An event's error record, failsafe mode change and firmware message merge into one finding, and the first anomaly before the crash leads the report. 12 read-only tools add an incident timeline, a two-flight comparison, a ready-to-post forum report and harmonic notch/PID advice. A fixed engine decides, not the AI.

04 · Solution

MCP Integration, Offline & Read-Only

Works with any MCP client (Claude, Cursor, VS Code, LM Studio…) and any model, local ones included. The log never leaves the machine: the server does not touch the network, send commands to a vehicle or write parameters. On the MCP Python SDK 2 it speaks both the 2026-07-28 protocol and the older handshake most desktop clients use. One line installs it from PyPI ("uvx ardupilot-mcp"); it is listed on the official MCP Registry.

05 · Result

Outputs & Results

With 1.0.0 the tool set, report schema and check catalogue are under semantic versioning. The engine is measured on 49 real crash logs from the ArduPilot forum, each labelled with the cause stated by a developer or an experienced helper who analysed it. Vehicle-aware: a multirotor check never runs on a helicopter's swashplate servos. Open source under AGPL-3.0 (0.1.3 and earlier stay MIT), with a test suite, a benchmark harness and documentation generated from the code.

Live status

Last checked: October 19, 2026

Version, store rating and latest changes are read from the repo and the stores every day.

PyPIv1.0.0Oct 18, 2026
MCP Registryv1.0.0io.github.furkanisikay/ardupilot-mcp
Source versionv1.0.0Last update: Oct 18, 2026
Commits, last 90 days19

Latest changes

  1. v1.0.0October 18, 2026

    • FixedArming refusals were dropped as boot chatter when they contained "calibrated" or " ready" ("PreArm: Compass calibrated requires reboot", "Arm: GPS not ready"), and an "Arm:"…
    • FixedFields compared sample by sample (ATT demand vs actual, GPS HDop vs Status, MAG X/Y/Z, BAT Volt vs Curr, the RCIN primary channels) were read one by one and paired by index, so…
    • FixedThe battery thresholds counted samples taken before arming (a monitor reads 0 V before the pack is connected) and any momentary sag. A threshold now counts only within one…
    • Fixed"Sudden voltage drop" kept only the largest step; when that was a glitch that recovered, a smaller drop that persisted went unreported. The largest persistent step is reported,…

    +62 more changes

  2. v0.1.3October 17, 2026

    • FixedPinned mcp to >=1.27,<2. mcp 2.0 (July 2026) removed mcp.server.fastmcp, so fresh installs (uvx ardupilot-mcp, pip install ardupilot-mcp) crashed on startup with…
    • Added.oss-scanner/Dockerfile and .oss-scanner/threat_model.md for Anthropic's OSS Scanner.
    • AddedA security contact email in SECURITY.md.
  3. v0.1.2June 14, 2026

    • AddedOne-click "Add to X" install buttons (Cursor, VS Code, VS Code Insiders, LM Studio) and per-client setup snippets for Claude Code, Claude Desktop, Cursor, VS Code, Antigravity…
    • Addedserver.json — Model Context Protocol registry manifest (PyPI package, stdio transport).
    • AddedClaude Code plugin: .claude-plugin/plugin.json, .claude-plugin/marketplace.json, a root .mcp.json, and a /diagnose command that drives a full log diagnosis with the tools.
    • AddedBeginner onboarding in both READMEs: a plain-language opener (what it is, and that it plugs into an AI client), a 5-minute Quick start with one client, a "where to get a .bin…

    +2 more changes

Diagnosis Flow (log → engine → explanation)

  1. 1.bin / .tlogBlack box or telemetry log
  2. 2Deterministic Engine18 checks, sourced thresholds
  3. 3AI ClientChat via Claude / Cursor / VS Code
  4. 4Finding + Doc LinkEvery finding links official ArduPilot docs

Need a similar solution?

We can deliver a custom solution like this one — or in the same field — end to end, together.

For example:Autonomous system softwareAI & computer visionCustom software development
First step
Discovery & Feasibility — Free
Requirements analysis · Technical roadmap · Rough plan and proposal document. Discovery and feasibility are free. The price and timeline of the project itself depend on its scope and come as a firm quote at the end of that work.

I'll build the same for you

Tell the assistant what you need — we will talk through whether I can build something like this, the approach and the free first step right away, and it books a time that suits you.

Book a free discovery call
  • Free 30-minute discovery call
  • Developer of the Teknofest 2021 champion UAV software
  • From a single consult to end-to-end delivery