Home
Teknofest 2021 · Turkey ChampionTeknofest 2021 Gold Medal

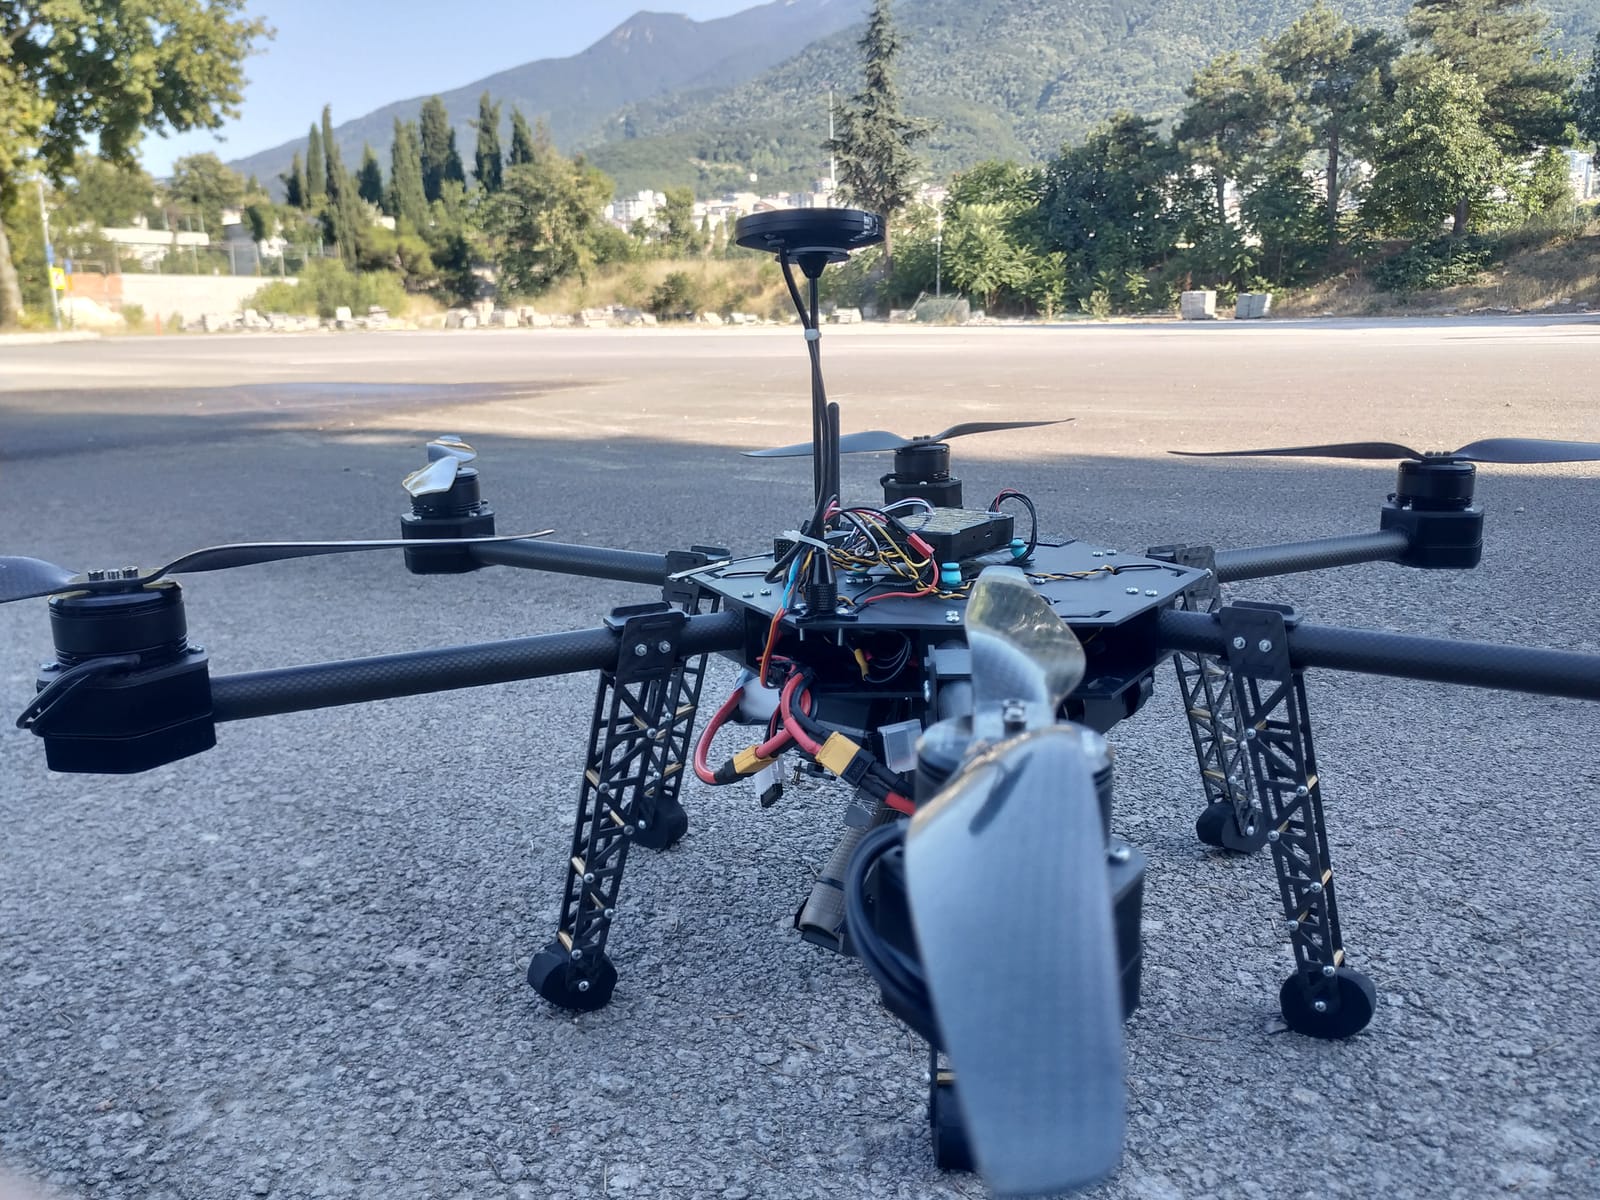
KAPGAN Combat UAV

National champion and winner of the "Most Original Software" award at Teknofest 2021 Combat UAV Competition — I was the sole developer of all three software units.

KAPGAN Combat UAV

Highlights

target lock
0,1 sn
continuous tracking
10 sn
stable in wind
30–35 km/s
autonomous control range
40+ km
Role
Sole software lead (3 units)
Period
2020 – 2021
Field
UAV and drones · Autonomy, AI and vision
Status
Teknofest 2021 · Turkey Champion

Tech stack

  • Python
  • OpenCV
  • Faster R-CNN
  • C#
  • .NET WinForm
  • MAVLink
  • Multi-threading
01 · Overview

Overview

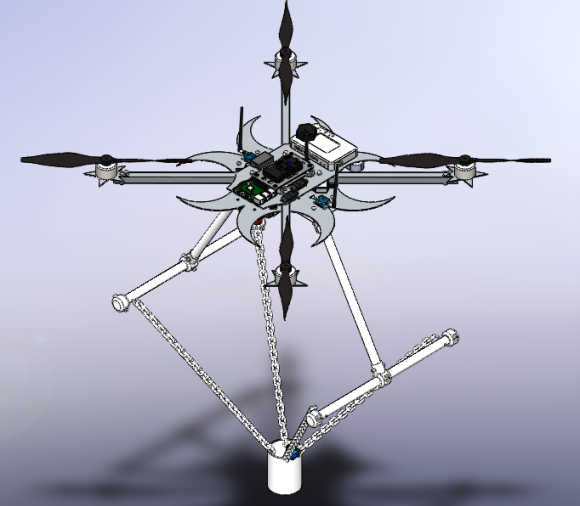
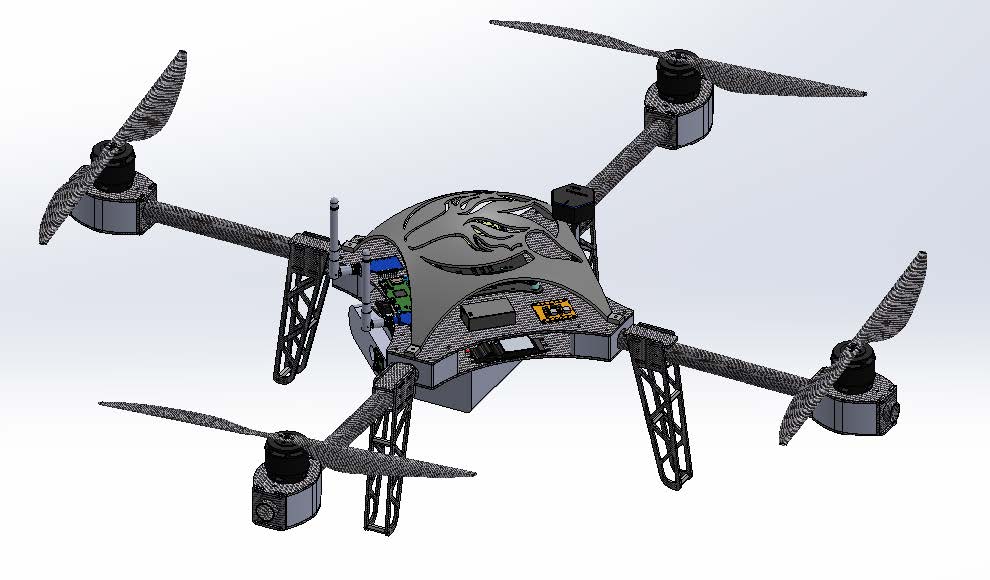
KAPGAN is the autonomous combat UAV we built with Team ÖZTÜRK for the Teknofest 2021 Combat UAV Competition. I single-handedly coded all three software units — the AI unit (the "eyes"), the main management unit (the "brain") and the ground control station (the "operator").
02 · Problem

The Problem

The combat mission requires recognising a rival UAV from the camera, locking onto it and tracking it for a set time — fully autonomously, within seconds, and stably on a windy field. That demanded a robust perception-to-action autonomy chain.

03 · Solution

AI Unit

I trained a Faster R-CNN model with Python and OpenCV to recognise drone bodies and detect target UAVs from the camera feed in real time, streaming detections to the main management unit.

04 · Solution

Management Unit & Ground Control Station

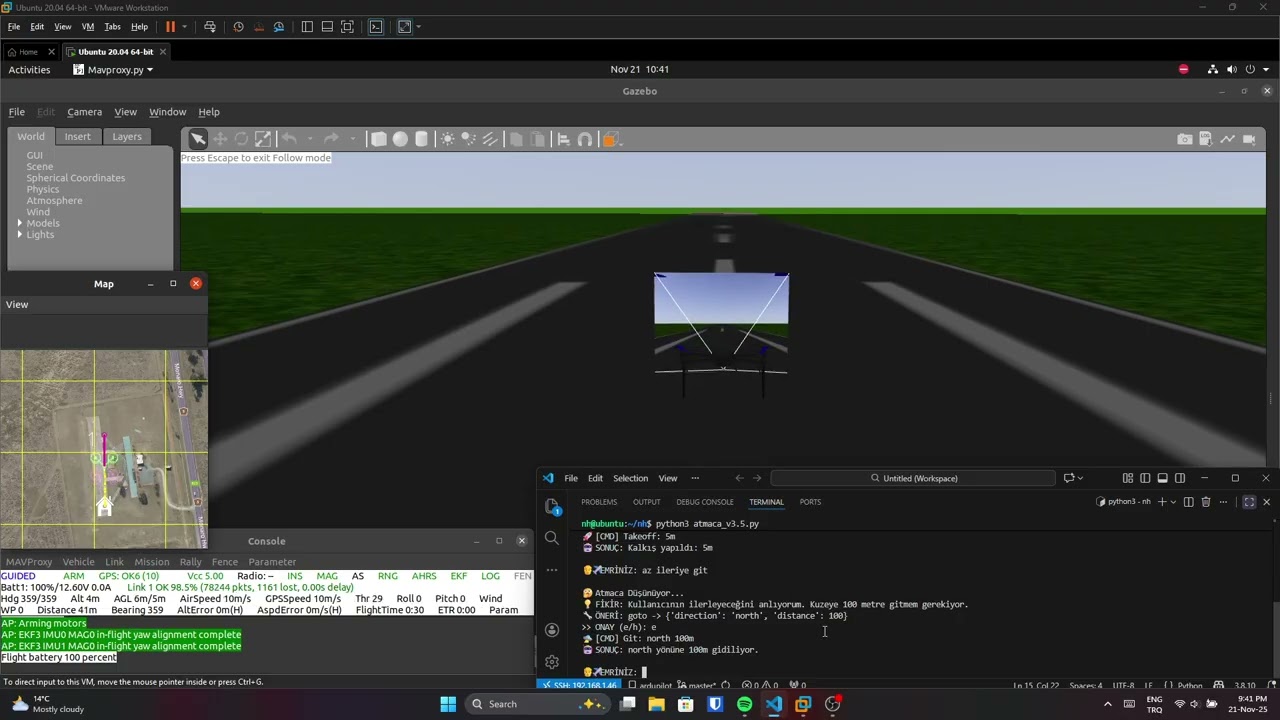
I wrote the main management unit in Python with multi-threading: it evaluated detections and sent autonomous engagement commands to the flight controller over MAVLink. The ground control station was built in C# / .NET WinForm with a layered architecture and a MaterialSkin UI, including telemetry sharing with the competition server and a module that emulates that server for testing.

05 · Result

Outputs & Results

We won the national championship and the "Most Original Software" award. The system recognises and locks onto a target in 0.1 s and tracks it for 10 s, flies stably in 30-35 km/h winds, stays airborne for 25-35 minutes, has a 40+ km autonomous-control range and streams live video from 5 km.

Autonomy Flow (camera → decision → engage)

  1. 1FrameLive camera feed
  2. 2AI DetectFaster R-CNN target detection
  3. 3DecideManagement unit (Python) engagement logic
  4. 4Lock & Track0.1 s lock, 10 s track
  5. 5TelemetryC# GCS streams data to server

3D Model

Drag to turn it; tap a number.

Parts and what they did

Videos

Aiming for an autonomous / AI-powered UAV?

I can build the full stack — real-time vision, an autonomous engagement algorithm and ground-control software — like in KAPGAN.

For example:AI target detection & trackingAutonomous mission software (Python/MAVLink)Custom ground control station
Outcome of this project
Turkey Champion · Most Original Software Award
First step
Discovery & Feasibility — Free
Requirements analysis · Technical roadmap · Rough plan and proposal document. Discovery and feasibility are free. The price and timeline of the project itself depend on its scope and come as a firm quote at the end of that work.

I'll build the same for you

Tell the assistant what you need — we will talk through whether I can build something like this, the approach and the free first step right away, and it books a time that suits you.

Book a free discovery call
  • Free 30-minute discovery call
  • Developer of the Teknofest 2021 champion UAV software
  • From a single consult to end-to-end delivery