Home
Teknofest 2020 · Autonomous firefighting

ABRA Autonomous Fire-Fighting UAV

A rotary-wing UAV carrying a water tank and flying autonomous routes, built for the fire-extinguishing theme of the Teknofest 2020 TÜBİTAK UAV competition.

ABRA Autonomous Fire-Fighting UAV
Role
Autonomous control & communication software
Period
2020
Field
UAV and drones · Autonomy, AI and vision
Status
Teknofest 2020 · Autonomous firefighting

Tech stack

  • Python
  • Multi-threading
  • C#
  • Gazebo
  • MAVLink
01 · Overview

Overview

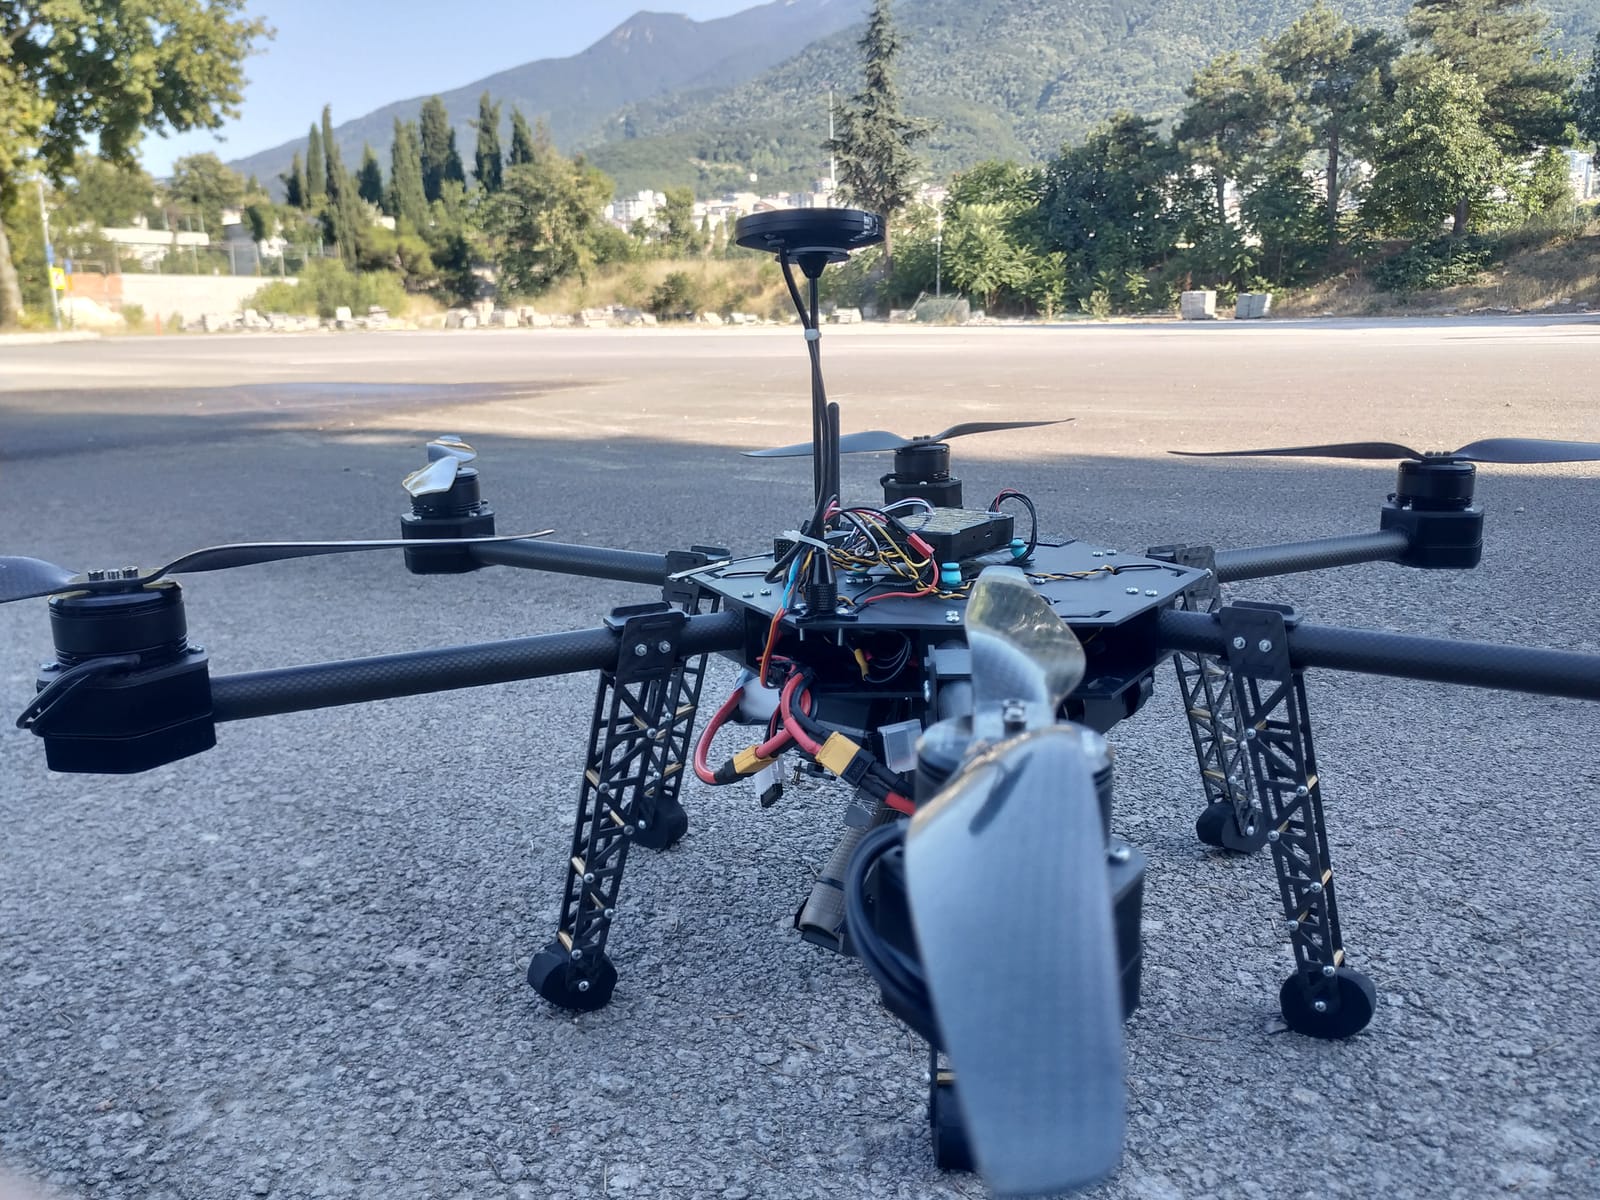
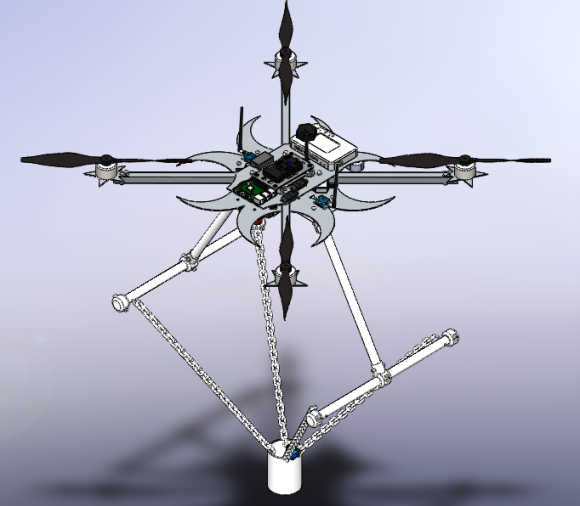
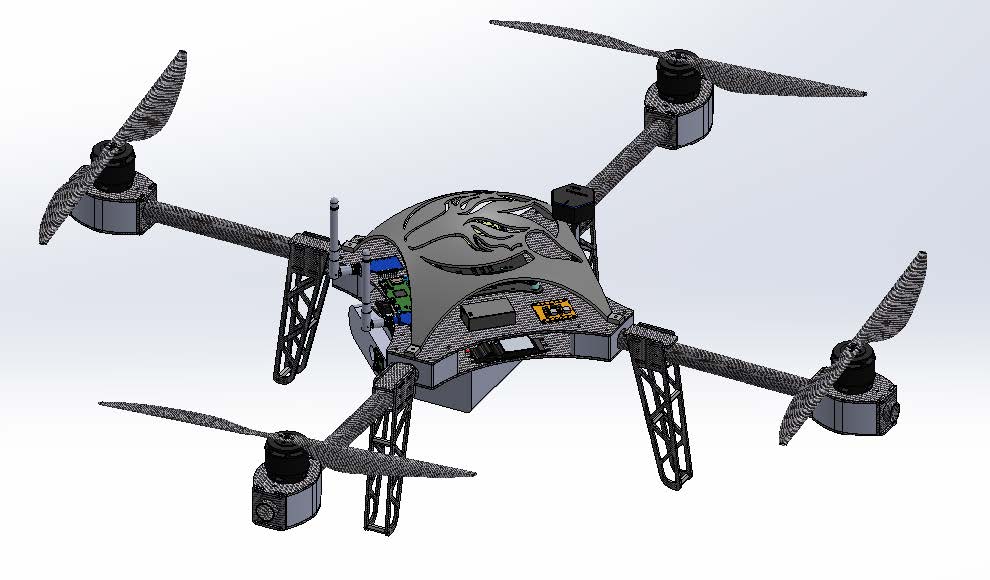
ABRA is the rotary-wing UAV we built as Team ÖZTÜRK for the fire-extinguishing theme of the Teknofest 2020 TÜBİTAK UAV competition. Carrying a water/extinguishant tank underneath, it was designed to autonomously reach the target and complete the mission.
02 · Solution

My Role

I coded the UAV's autonomous control software in Python with a multi-threading architecture, and built the communication software as a C# desktop app ("ABRA MCU GCS"). The ground station sent labelled mission points (start/end coordinates) to the UAV, which flew the route autonomously; the GCS could also start/stop the autonomy unit remotely.

03 · Solution

Simulation Validation

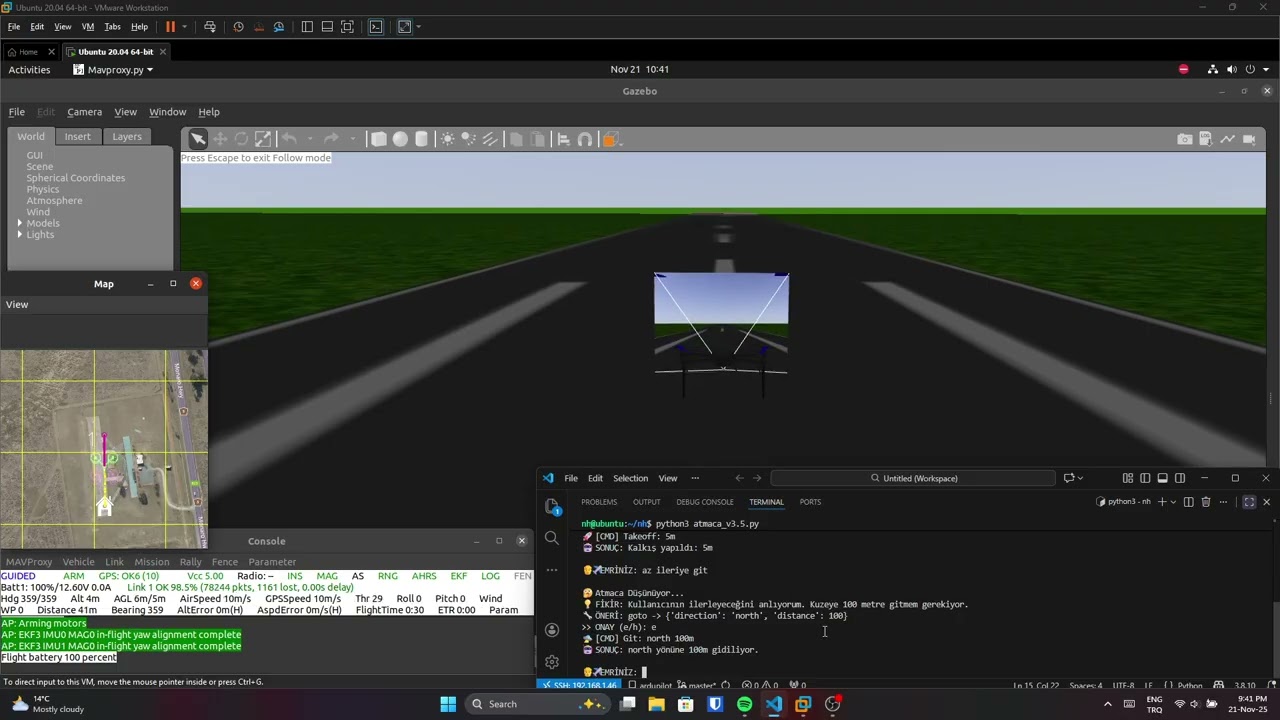
I validated the autonomous mission logic in Gazebo + MAVProxy by running waypoint missions with real coordinates — testing behaviour before any real flight.

04 · Result

Outputs & Results

The result was a working autonomous control + ground control software; we were eliminated at the final-report stage. Even so, multi-threaded autonomous flight in Python and a C# ground station matured here and paved the way for the national championship a year later (KAPGAN).

Autonomous Mission Flow

  1. 1Send RouteMission points from GCS (C#)
  2. 2Autonomous FlightPython + multi-threading
  3. 3Fire DetectionLocate the target zone
  4. 4ApproachAutonomous approach
  5. 5ExtinguishRelease water/extinguishant

Planning an autonomous mission drone (fire, search, cargo)?

I develop multi-threaded autonomous control plus a desktop mission/ground-control app, and validate it in Gazebo before any flight.

For example:Autonomous waypoint missionsMission-planning interface (GCS)Validation in simulation
First step
Discovery & Feasibility — Free
Requirements analysis · Technical roadmap · Rough plan and proposal document. Discovery and feasibility are free. The price and timeline of the project itself depend on its scope and come as a firm quote at the end of that work.

I'll build the same for you

Tell the assistant what you need — we will talk through whether I can build something like this, the approach and the free first step right away, and it books a time that suits you.

Book a free discovery call
  • Free 30-minute discovery call
  • Developer of the Teknofest 2021 champion UAV software
  • From a single consult to end-to-end delivery