01 · Overview
Overview
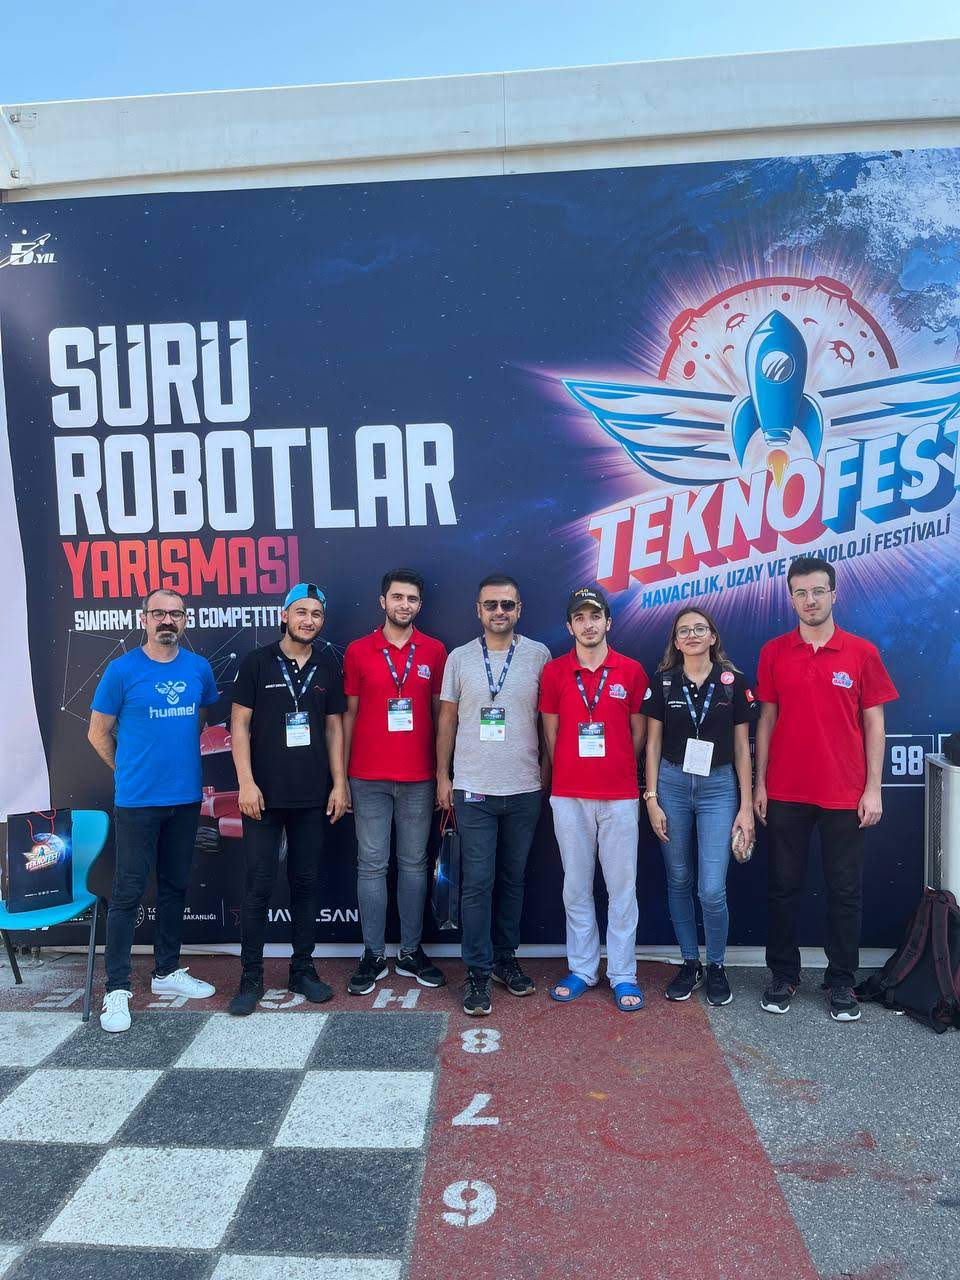
We competed in the Teknofest 2022 Swarm Robotics Competition as İLTER YAZILIM, the team of the Science, Idea and Art community. I served as software team lead and built the swarm controller software.
Teknofest 2022 Swarm Robotics finalist. As software team lead, I built the swarm control algorithm coordinating nano-drones over ROS.
Tech stack
We competed in the Teknofest 2022 Swarm Robotics Competition as İLTER YAZILIM, the team of the Science, Idea and Art community. I served as software team lead and built the swarm controller software.
The system ran on a ROS "Master–Slave" topology: the referee (Master) PC published obstacle and target positions as ROS topics, while our team software (Slave) published our drones' poses and listened to rivals' and obstacles' positions to compute collision-free swarm motion. I controlled Crazyflie 2.0 nano-quadcopters over Crazyradio PA in Python, running takeoff/landing and position commands concurrently by assigning a thread per drone.
The competition had three tasks: obstacle avoidance, a cargo-carrying race against a rival swarm (collision avoidance via shared poses), and a mixed-swarm fire-extinguishing task together with a ground robot.
We placed 6th among the 10 finalist teams. I built swarm control software that coordinates multiple autonomous aerial vehicles in real time, collision-free — reaching the finals on our first swarm-robotics attempt.
I can develop the ROS-based swarm control that coordinates multiple vehicles in real time, collision-free.
Tell the assistant what you need — we will talk through whether I can build something like this, the approach and the free first step right away, and it books a time that suits you.
Book a free discovery call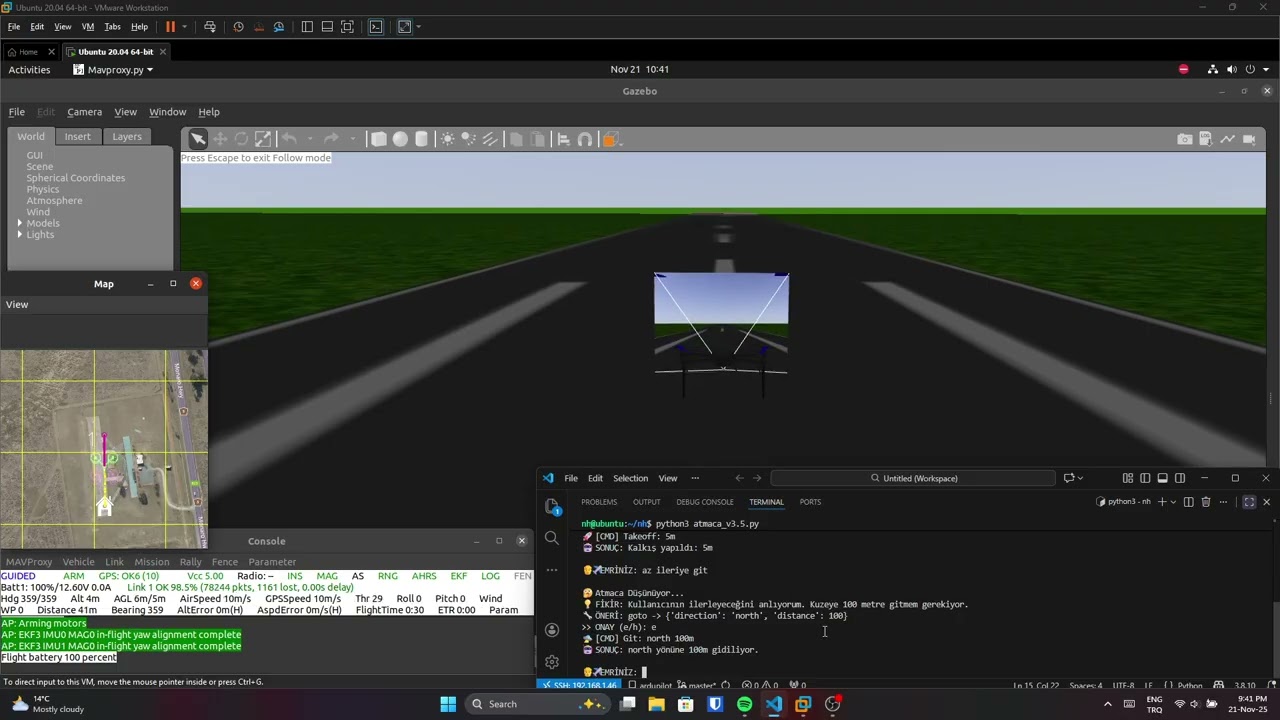 Open source · R&DAtmaca — LLM-Powered Autonomous UAVAn experimental UAV you command in plain (natural) language; a language model (Gemma 3) interprets the commands and turns them into autonomous flight.
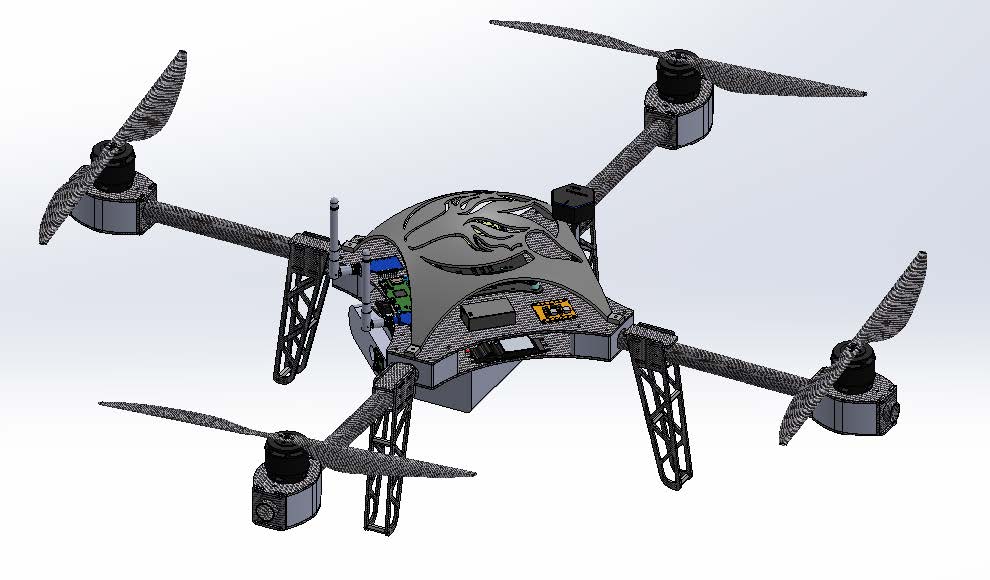 Teknofest 2021 · Turkey ChampionKAPGAN Combat UAVNational champion and winner of the "Most Original Software" award at Teknofest 2021 Combat UAV Competition — I was the sole developer of all three software units.
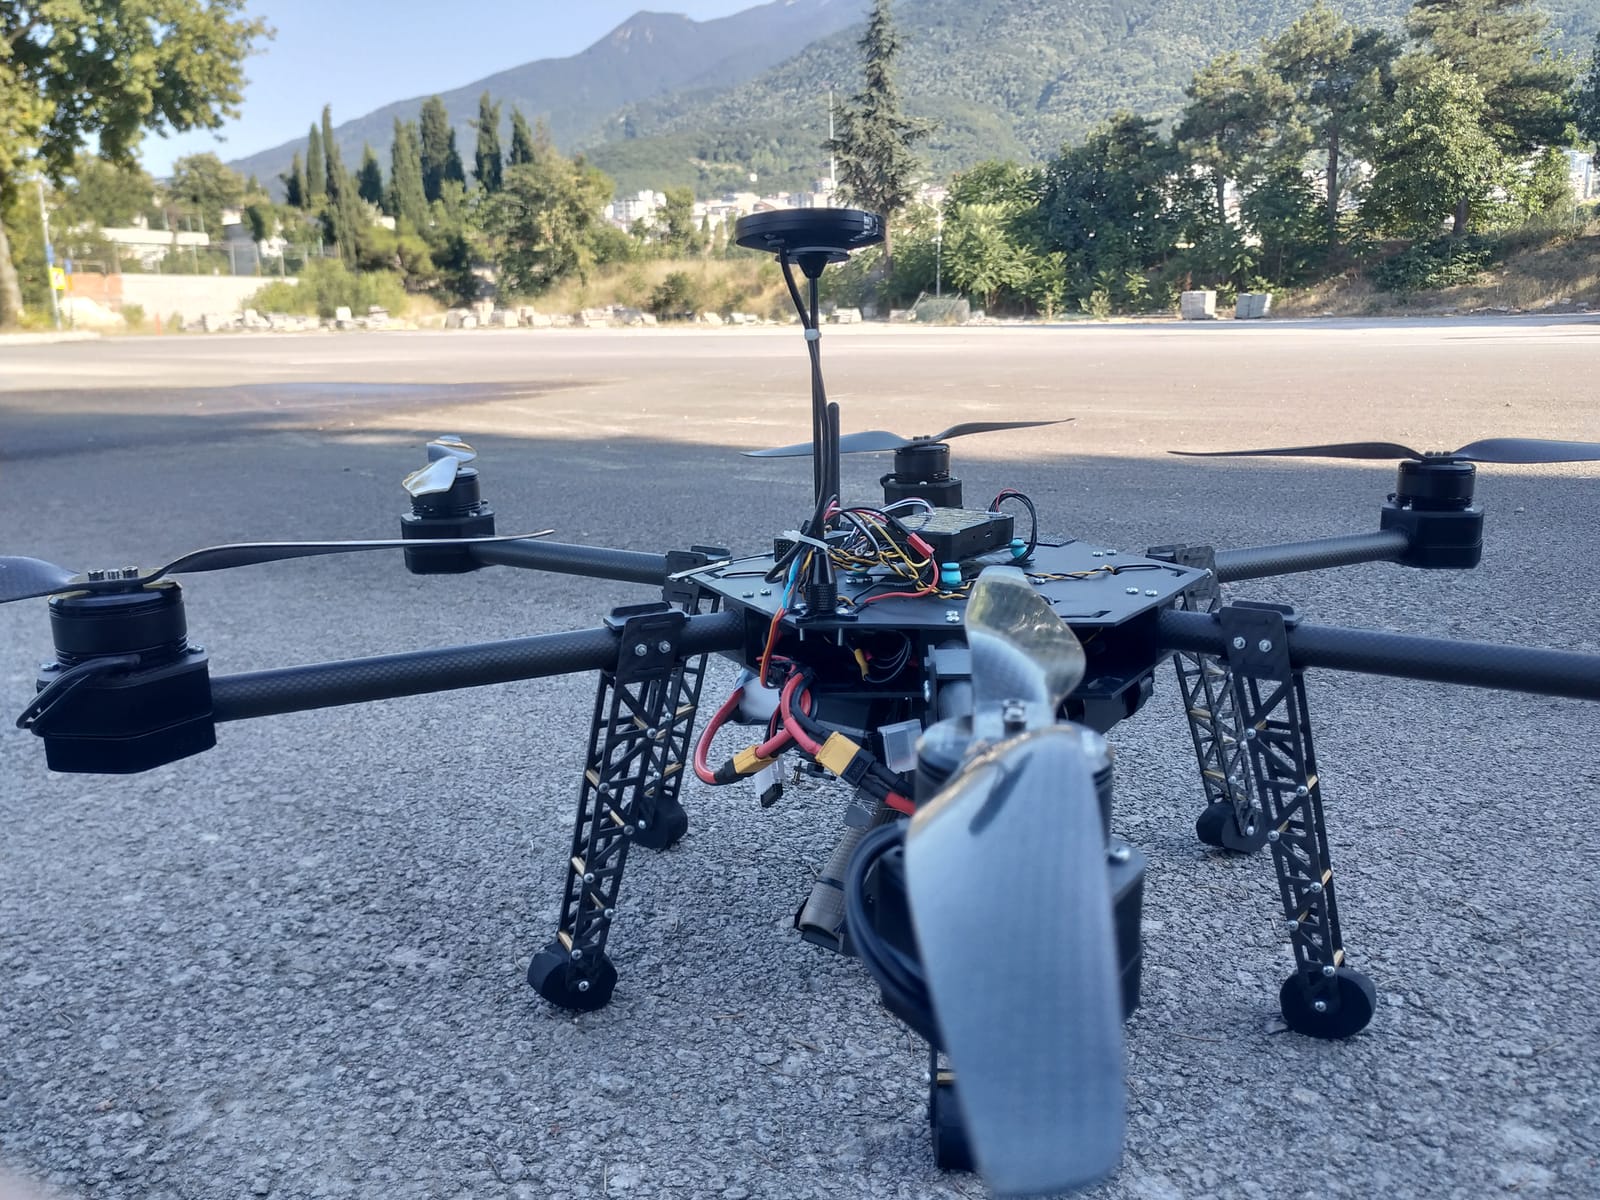 Teknofest 2022 · Finalist (9th)Armed Autonomous Strike UAVTeknofest 2022 TÜBİTAK Open-Mission UAV finalist: a hexacopter that runs the entire mission — from takeoff to strike — autonomously. I coded its "brain", the main management unit.