01 · Overview
Overview
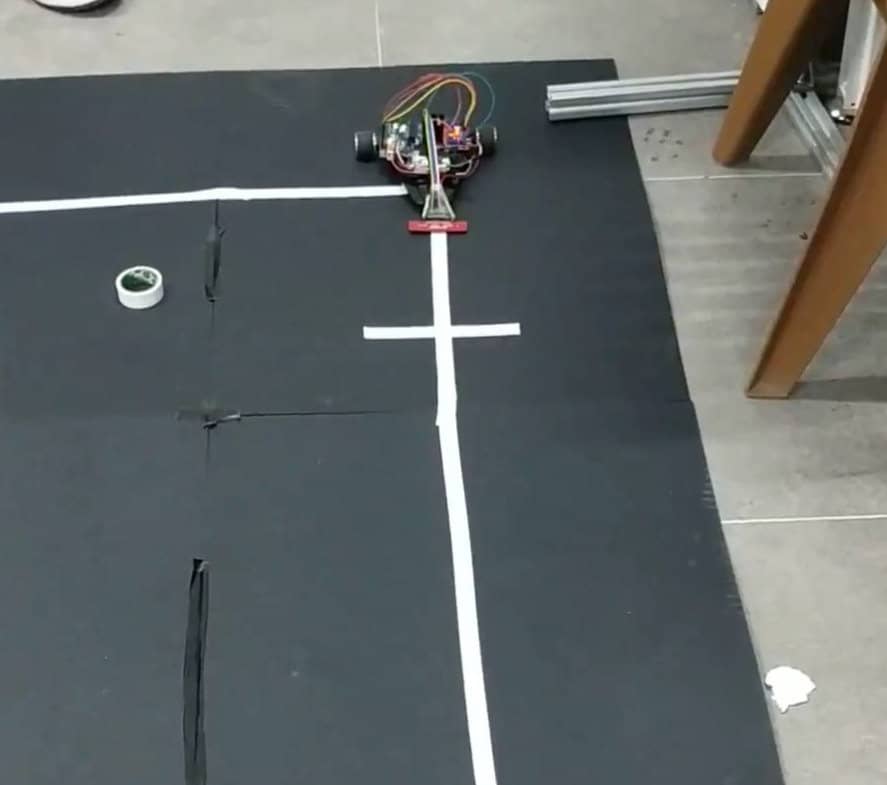
Before even starting my actual department, during prep year, I joined the MATRO community's line-following robot team and worked on the embedded-systems (C/C++) coding of the project.
My first robotics team project, in the MATRO community during my university prep year, where I owned the embedded-systems coding.
Tech stack
Before even starting my actual department, during prep year, I joined the MATRO community's line-following robot team and worked on the embedded-systems (C/C++) coding of the project.
Line sensors read the surface, an Arduino computed direction/speed via PID control, and the motors were driven accordingly. This was the first project where I learned closed-loop control hands-on.
A robot that followed the line stably — where my interest in embedded software and control theory began.
I develop Arduino/embedded robotics with sensor integration and closed-loop control algorithms like PID.
Tell the assistant what you need — we will talk through whether I can build something like this, the approach and the free first step right away, and it books a time that suits you.
Book a free discovery call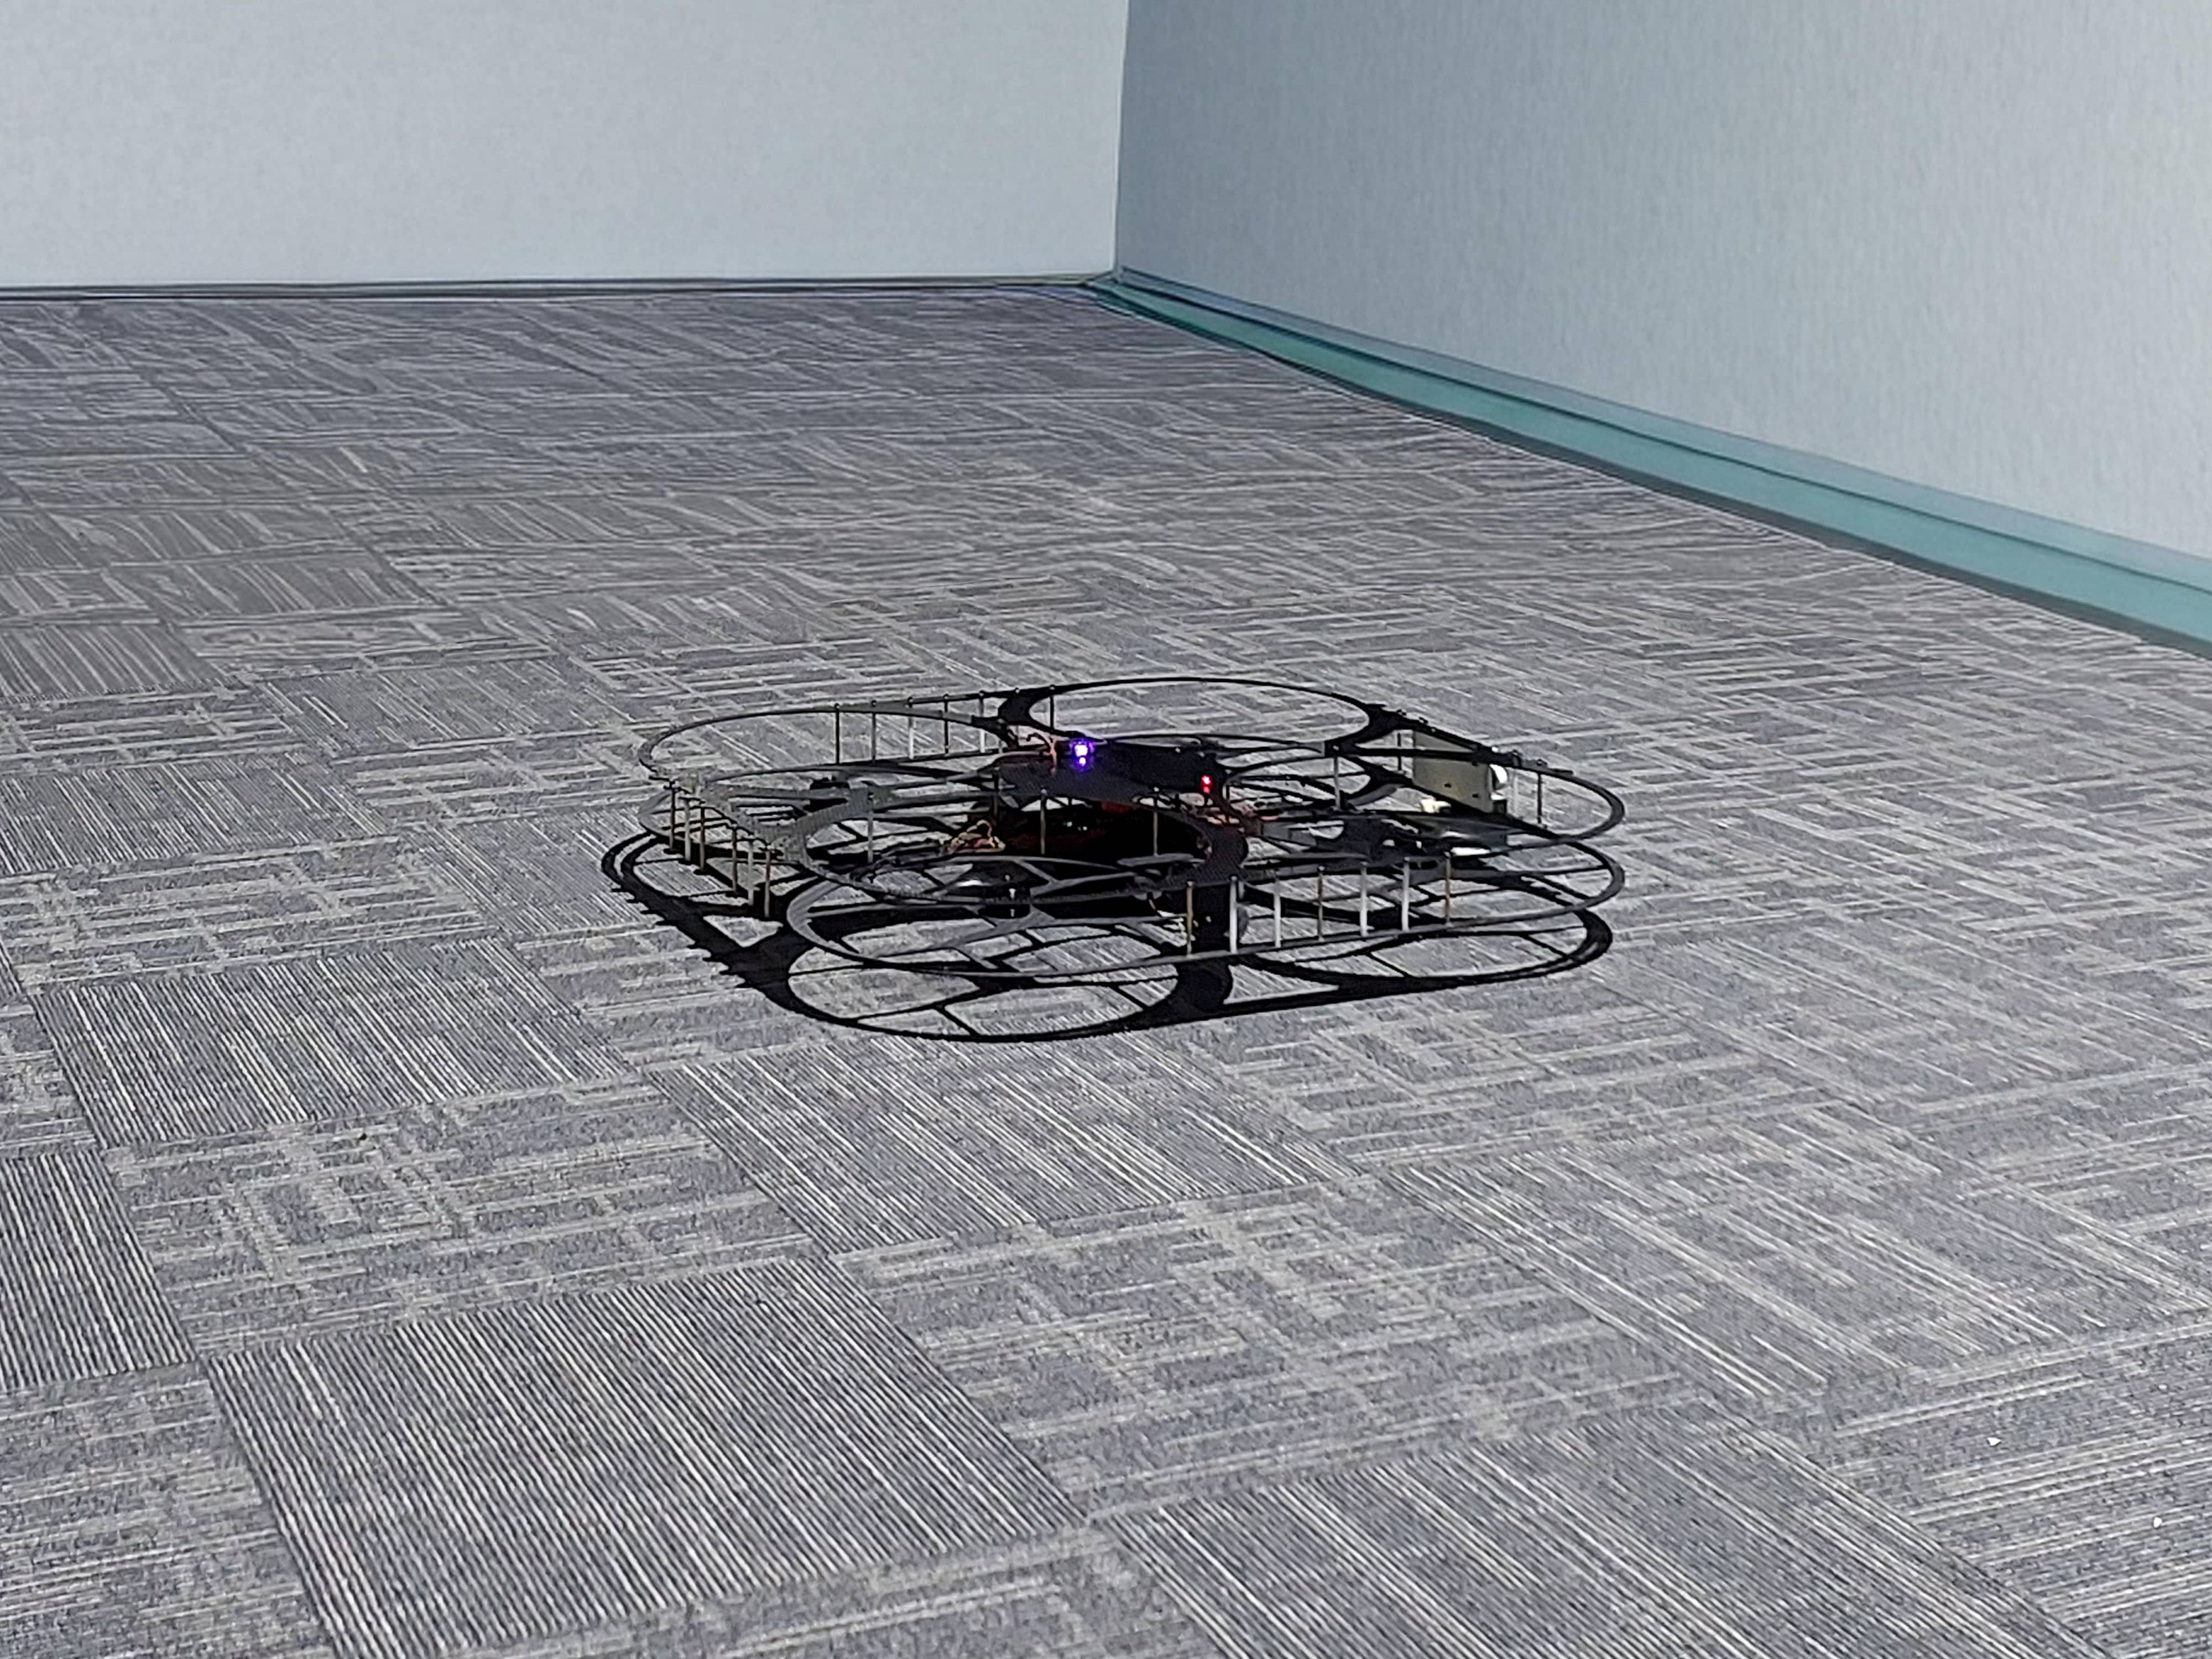 Mayfly · Turkey's first GPS-denied 5G UAV5G-Enabled GPS-Denied UAVOne of Turkey's first private-5G UAVs able to operate in GPS-denied (indoor/factory) environments. We built one drone in 15 days; I owned the system architecture and the control/communication software.
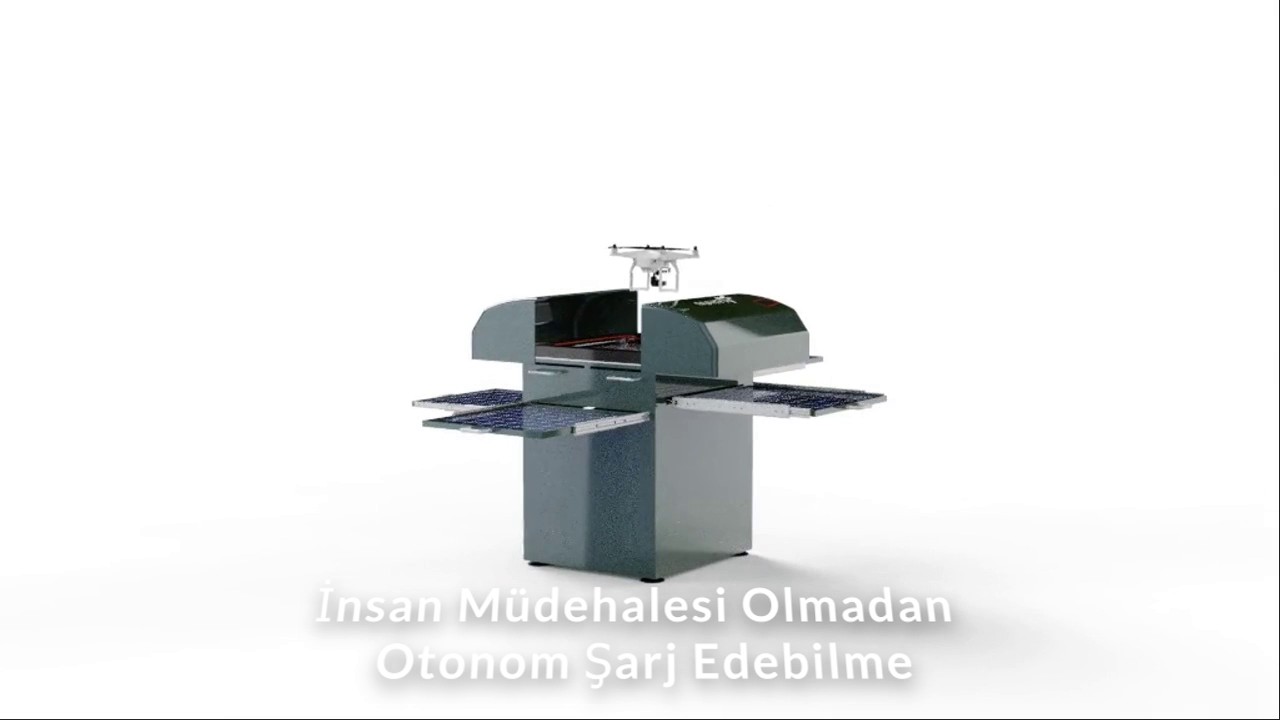 Mayfly · KOSGEB Advanced Technology projectAutonomous Drone Charging StationA solar-assisted, fully autonomous wired charging station that talks MAVLink. It was Mayfly's KOSGEB advanced-technology project; I designed the system architecture and wrote all the embedded firmware single-handedly.
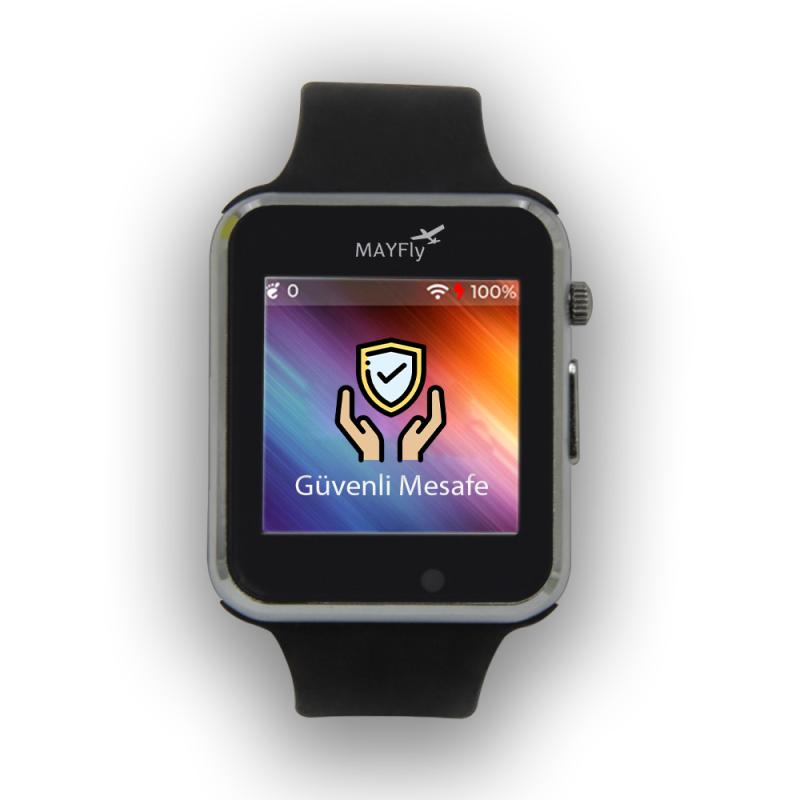 Mayfly · My first industrial projectSmart Social-Distancing WristbandMy first industrial project, run solo from hardware to design to software. Built at Mayfly for Bursa Ekol College — an ESP32 + C++ wristband measuring distance to cm precision.