Home
My first international freelance job · Upwork/Fiverr

Vision-Based Autonomous Precision Landing

A precision-landing system that uses AI to detect a helipad "H" marking and lands the drone exactly on its centre — continuously re-centring during descent so wind/drift cannot throw it off. My first serious international freelance job.

Role
Sole developer (freelance)
Period
2024
Field
UAV and drones · Autonomy, AI and vision
Status
My first international freelance job · Upwork/Fiverr

Tech stack

  • Python
  • YOLOv3-tiny
  • OpenCV (DNN)
  • DroneKit
  • MAVLink
  • ROS / Gazebo
  • ArduPilot SITL
01 · Overview

Overview

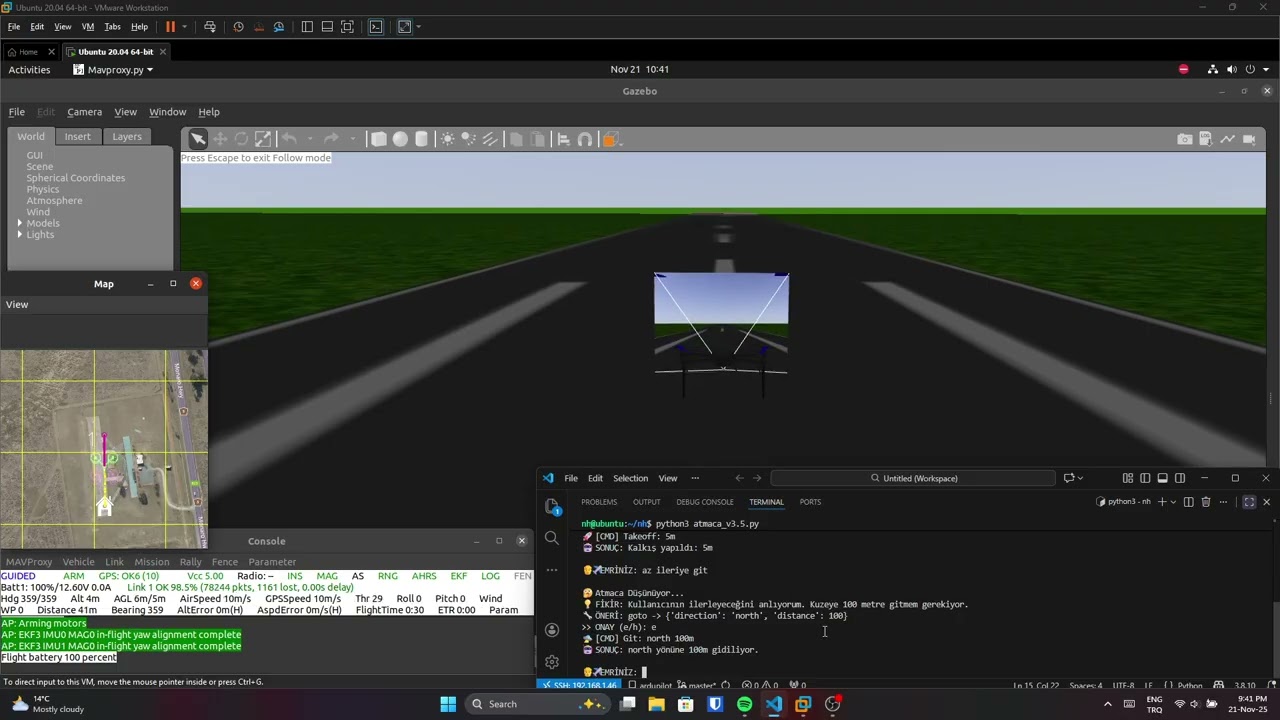
A precision-landing system I delivered in ~2-3 days for an international client via Upwork/Fiverr — my first serious paid international freelance job. A downward-facing camera on the drone detects the helipad "H" marking in real time, and the system brings the drone to the exact centre of that marking before touching down.
02 · Problem

The Problem

It had to land on the exact centre of a helipad whose position is not known in advance (variable), despite wind and drift. Landing on a fixed GPS point isn't enough — the target can shift at the moment of touchdown.

03 · Solution

How It Works

I detect the "H" with a custom single-class YOLOv3-tiny model (on OpenCV's DNN module). It picks the largest box (nearest pad), finds its centre and computes the offset from the camera centre. A control loop with a dead-zone threshold issues short body-frame (NED) velocity commands (DroneKit + MAVLink) to close the offset. Once centred enough, it switches to ArduPilot LAND mode; it keeps tracking the "H" throughout the descent, makes corrective manoeuvres if it drifts, and disarms the motors on ground contact.

04 · Result

Outputs & Status

I delivered an end-to-end system running in Gazebo + ArduPilot SITL that performs the whole takeoff–search–centre–autonomous-landing loop (demo video on the cover). Since the architecture is DroneKit/MAVLink, it ports to a real ArduCopter vehicle.

Detect → Centre → Autonomous Land

  1. 1CameraDownward camera feed
  2. 2H DetectionYOLOv3-tiny (OpenCV DNN)
  3. 3Centre & OffsetBox centre ↔ camera centre
  4. 4Re-centreNED velocity (DroneKit/MAVLink)
  5. 5Autonomous LandArduPilot LAND + disarm on contact

Looking for a precision / autonomous landing solution?

I can deliver, fast, a vision-based system that detects the target and lands dead-centre despite wind.

For example:Vision-based pad detectionAutonomous precision landingFast freelance delivery
First step
Discovery & Feasibility — Free
Requirements analysis · Technical roadmap · Rough plan and proposal document. Discovery and feasibility are free. The price and timeline of the project itself depend on its scope and come as a firm quote at the end of that work.

I'll build the same for you

Tell the assistant what you need — we will talk through whether I can build something like this, the approach and the free first step right away, and it books a time that suits you.

Book a free discovery call
  • Free 30-minute discovery call
  • Developer of the Teknofest 2021 champion UAV software
  • From a single consult to end-to-end delivery